---
updatedAt: 2026-09-16T22:23:50.000Z
agentTools:
projectIndex: https://docs.thousandbrains.org/llms.txt
---
# Project Showcase
A list of projects that utilize Monty or the TBT.
This page showcases some projects that were realized using the Monty code-base. If you have a project that you would like to see featured here, simply create a PR adding it to this page.
Please make sure your project is well documented, including a README on how to run it and ideally some images or video showcasing it. Feel free to also include a video or image here. Please also keep your description on this page short and concise.
# Monty for Object Detection With the iPad Camera
[block:embed]
{
"html": "",
"url": "https://www.youtube.com/watch?v=KcE004QbuSw",
"title": "2023/03 - Monty's First Live Demo in the Real World",
"favicon": "https://www.youtube.com/favicon.ico",
"image": "https://i.ytimg.com/vi/KcE004QbuSw/hqdefault.jpg",
"provider": "https://www.youtube.com/",
"href": "https://www.youtube.com/watch?v=KcE004QbuSw",
"typeOfEmbed": "youtube"
}
[/block]
This is the first real-world demo of Monty the TBP team came up with. We used the iPad camera to take an image of an object. Monty then moves a small patch over this image and tries to recognize the object.
See the [monty\_lab project folder](https://github.com/thousandbrainsproject/monty_lab/tree/main/monty_meets_world) for more details.
# LEGO Robot
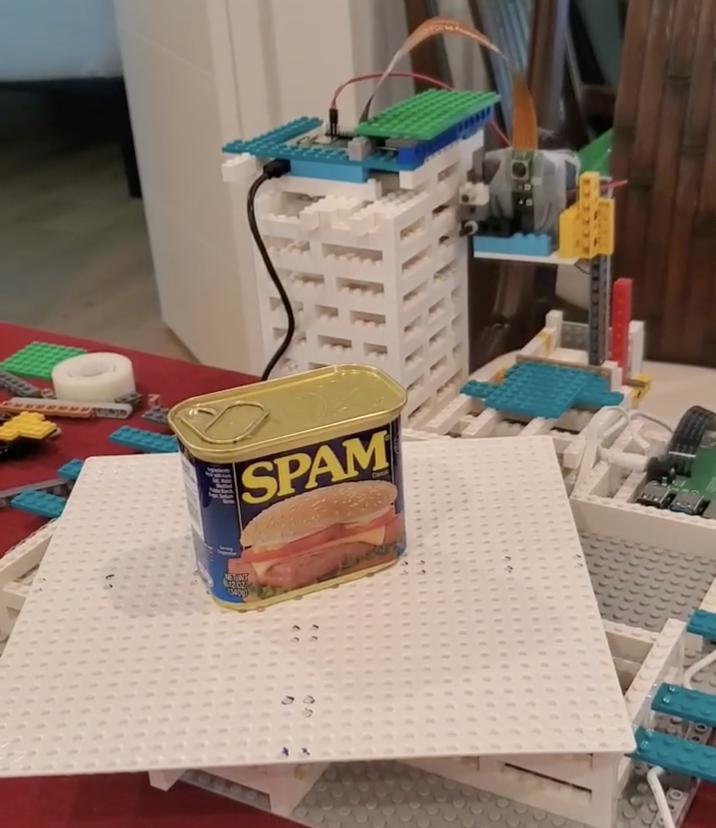
The first example of Monty moving its sensors in the real-world.
Follow the [LEGO tutorial](/docs/using-monty-for-robotics#example-3-lego-based-robot) to try this out yourself.
See the [everything\_is\_awesome repository](https://github.com/thousandbrainsproject/everything_is_awesome) for more information.
Watch the video:
[block:embed]
{
"html": "",
"url": "https://www.youtube.com/watch?v=_u7STtACQ50",
"title": "2025/05 - Robot Hackathon Presentations",
"favicon": "https://www.youtube.com/favicon.ico",
"image": "https://i.ytimg.com/vi/_u7STtACQ50/hqdefault.jpg",
"provider": "https://www.youtube.com/",
"href": "https://www.youtube.com/watch?v=_u7STtACQ50",
"typeOfEmbed": "youtube"
}
[/block]
# Ultrasound Perception
[block:embed]
{
"html": "",
"url": "https://www.youtube.com/watch?v=qhrHyTYVPgo",
"title": "Monty for Ultrasound - A Real World Challenge",
"favicon": "https://www.youtube.com/favicon.ico",
"image": "https://i.ytimg.com/vi/qhrHyTYVPgo/hqdefault.jpg",
"provider": "https://www.youtube.com/",
"href": "https://www.youtube.com/watch?v=qhrHyTYVPgo",
"typeOfEmbed": "youtube"
}
[/block]
Using sensorimotor AI to guide ultrasound.
Follow the [ultrasound tutorial](/docs/using-monty-for-robotics#example-2-ultrasound) for more details.
See the [ultrasound\_perception repository](https://github.com/thousandbrainsproject/ultrasound_perception) for more information. The repository also includes a downloadable dataset and benchmarks.
Watch the video of the first demo:
[block:embed]
{
"html": "",
"url": "https://www.youtube.com/watch?v=-zrq0oTJudo",
"title": "2025-05 Ultrasound Presentation and Demo",
"favicon": "https://www.youtube.com/favicon.ico",
"image": "https://i.ytimg.com/vi/-zrq0oTJudo/hqdefault.jpg",
"provider": "https://www.youtube.com/",
"href": "https://www.youtube.com/watch?v=-zrq0oTJudo",
"typeOfEmbed": "youtube"
}
[/block]
# Undergraduate Dissertation Community Project
## Robotic Object Recognition for Thousand-Brains Systems
**Author:** Zachary Danzig from Loughborough University\
**Links:** [tbp.monty Fork](https://github.com/Zinxiee/tbp.monty) | [Maixsense A010 Python Package](https://github.com/Zinxiee/Maixsense-A010-Python-Package) | [3D Model Dataset](https://github.com/Zinxiee/tbp.monty/releases/tag/dataset_scans_\(shining_3d\)) | [Robotic Object Recognition For Thousand Brain Systems.pdf](https://github.com/user-attachments/files/30555412/Robotic.Object.Recognition.For.Thousand.Brain.Systems.pdf)
This community project expands upon the Thousand Brains Project by designing and constructing a system capable of multimodal sensing and movement. The core aim is to enable the learning and recognition of real-world objects in a human-like way (sensorimotor learning), helping to bridge the framework's sim-to-real gap. While Monty has primarily been validated in simulated environments, this dual-agent sensorimotor system tests how Monty performs on physical hardware in the real world.\
**Dual-agent Sensorimotor Setup**\ \
*The dual-agent sensorimotor setup featuring the Ufactory Lite 6 with mounted A010 ToF sensor and Zed 2i stereo camera, with the mc\_fox object in view.*
### Key Features
* **Distant Agent Implementation:** Developed around the Zed 2i stereo camera to extend the existing [Monty Meets World](https://docs.thousandbrains.org/docs/project-showcase#monty-for-object-detection-with-the-ipad-camera) pipeline.
* **RGBD Scene Indexing:** Supports continual capture and indexing of RGBD scenes.
* **Surface Agent Implementation:** Built using a Maixsense A010 ToF sensor mounted to a Ufactory Lite 6 robot arm.
* **Custom Integration:** Integrated with Monty through a custom environment, environment interface, and motor-policy.
* **Hardware Tooling:** Includes a reverse-engineered Python package that exposes programmatic control of the Maixsense A010 sensor.
* **Object Dataset:** Evaluated the system against a structured eight-object dataset with defined orientations suitable for evaluating recognition accuracy, continual learning, and rotation invariance. As an extension to the project, a 3D Model Dataset was scanned in and made available to the community.
Note that this project does not integrate the different modalities at the same time. Each agent is run independently.
### Results and Findings
* The Distant Agent demonstrated reliable supervised recognition with sub-degree rotation errors.
* The Surface Agent exposed critical hardware limitations regarding Time-of-Flight (ToF) scattering on non-flat geometries which heavily restricted Surface Agent experiments.
* This work provides a real-world starting point for testing the framework's physical deployment and constraints.
[Surface Agent Demo with TBP Mug](https://youtube.com/shorts/E8tcEsyo7-U)
### Monty Meets World Proof of Concept
At the start of this project a proof of concept was demonstrated by reproducing the Monty Meets World Experiment above. For information on how this was done, see the following links: [Explanation](https://forum.thousandbrains.org/t/design-of-final-year-undergraduate-project-with-the-inclusion-of-the-tbp/417/30?u=zachary_danzig) | [Experiment YAML](https://github.com/Zinxiee/tbp.monty/blob/main/src/tbp/monty/conf/experiment/zachs_examples/zachs_monty_meets_world.yaml) | [Demo](https://youtu.be/a9u1Y3Amlxc).
For more about this project, visit the links above or see the [Discourse community topic](https://forum.thousandbrains.org/t/design-of-final-year-undergraduate-project-with-the-inclusion-of-the-tbp/417).
Watch the presentation:
[block:embed]
{
"html": "",
"url": "https://www.youtube.com/watch?v=3wgHNqkRekM",
"title": "07/2026 - Robotic Object Recognition for Thousand Brains Systems",
"favicon": "https://www.youtube.com/favicon.ico",
"image": "https://i.ytimg.com/vi/3wgHNqkRekM/hqdefault.jpg",
"provider": "https://www.youtube.com/",
"href": "https://www.youtube.com/watch?v=3wgHNqkRekM",
"typeOfEmbed": "youtube"
}
[/block]
***
#### Help Us Make This Page Better
All our docs are open-source. If something is wrong or unclear, submit a PR to fix it!
Make a Contribution
[Learn how to contribute to our docs](/docs/documentation)